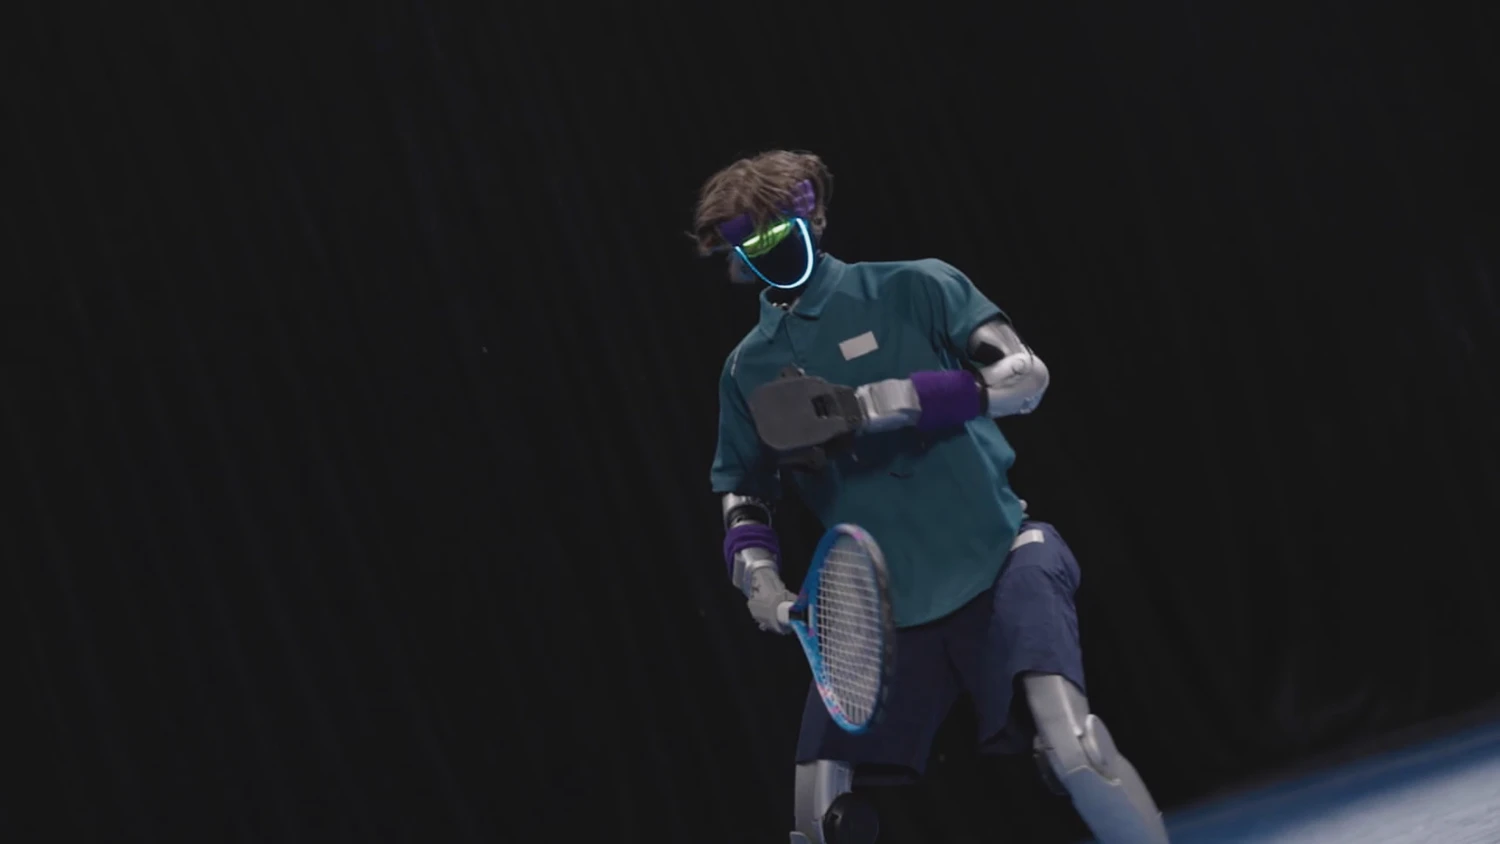
AdaPT teaches humanoid robots tennis motions with adaptive planning and tracking
AdaPT is a research framework that learns tennis serve and rally styles from broadcast video and motion-capture data. A high-level planner generates motion while a lower-level tracker executes it. Training across random execution speeds and a learned motion-speed adapter help the planner account for imperfect tracking on physical robots. The research team reports experiments on Unitree G1 and a full-size Dobot Atom humanoid, including serving outside a motion-capture setting. That serving experiment still uses camera-based ball localisation and robot localisation tools; it is not evidence of professional match-level autonomy or a commercial sports robot. The Wiley overview describes the same research covered in the team's August 2026 arXiv manuscript and project page. Authors include researchers from Noitom Robotics, Shanghai AI Laboratory, Dobot Robotics and Shanghai Jiao Tong University. The result concerns adaptation across simulation and hardware, with limitations from tracking error and noisy perception still part of the engineering problem.
DTT summary based on IEEE Spectrum's report. The full article is on the publisher's site.
Additional reporting
Adaptive motion planning and tracking
Unitree G1 and full-size Dobot Atom
Research demonstration